Hello All,
I'm in the middle of an interesting project involving the tinyG controller and a camera attached to an XY gantry system. The idea is to move the camera along predefined gcode paths and take reproducible video of a subject with different gantry motions.
Anyway I had a few questions below - thanks to all in advance for your help:
1) On the tinyG wiki for comms (https://github.com/synthetos/TinyG/wiki/Tinyg-Communications-Programming) under linemode protocol there is a bullet point:
When a {r:...} response comes back from the g2core, add one to lines_to_send.
It's vital that when any {r:...} comes back that lines_to_send. If one is lost or ignored then the system will get out of sync and sending will stall.
"It's vital that when any {r:...} comes back that lines_to_send." seems to be missing a word or two - I assume it wants to say that lines_to_send is incremented but wanted to be sure since its marked 'vital'.
2) Our priorities for motion differ from a typical system - smooth acceleration/deceleration and basically no jerk at all. The values I've tuned to are very different than most I've seen but its a result of lots of iteration around getting smooth, consistent motion for the camera (though I'm sure there is lots to go!). If anyone has any advice on good tweaks that would be great. Right now results are somewhat inconsistent.
- a parabolic test path of 60 points/gcode commands runs smoothly during the middle but the start and finish are fairly harsh/jerky
- A three point/gcode command '7' shaped path runs smoothly throughout
- A parabolic test path of 7 points/gcode commands exhibits some pretty harsh start/stop/stutter as it navigates to different points.
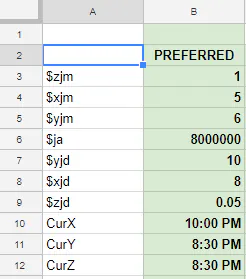
the image object seems to not work... link to settings: https://imgur.com/iujnoj8
xjm/xjm/yjm are x 1million, xjd/yjd/zjd are in mm.
Only X and Y axis are responsible for motion.
Thanks again!