Hi,
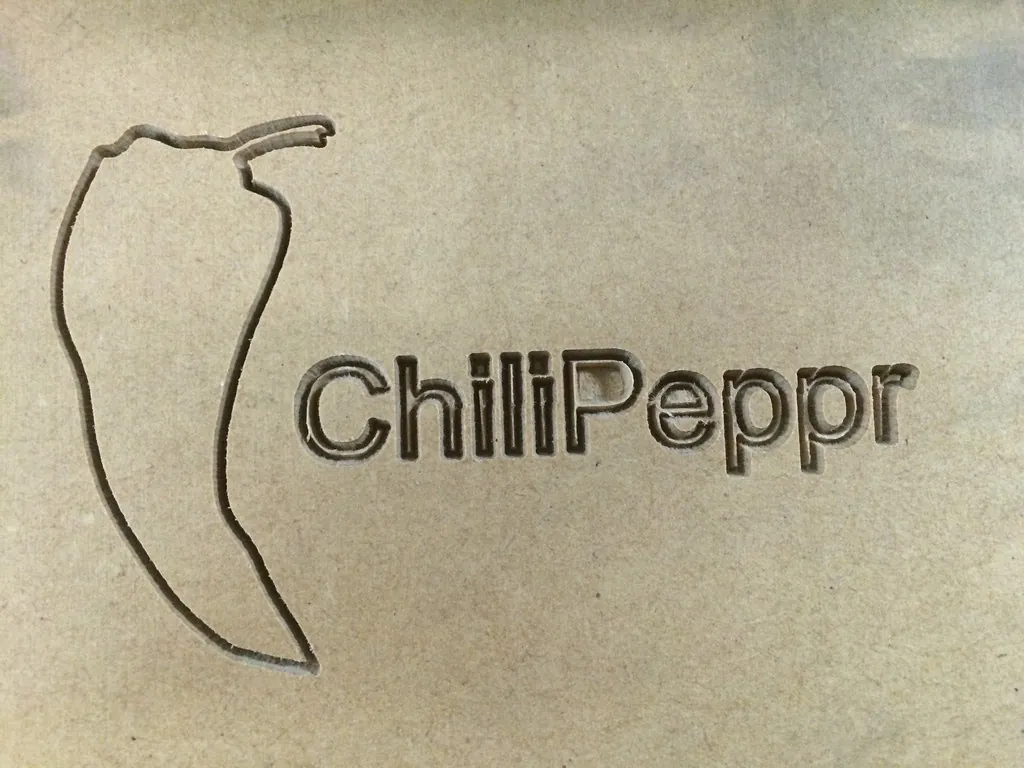
I'm building a large wood router with my son Bram (11y) and are using the TinyG v8 to drive it. We're also using the TinyG v8 in a 3040 Chinese CNC router and that runs perfect. The g-code file on the 3040 CNC router turns out great but the same file on the bigger router gives different shapes.
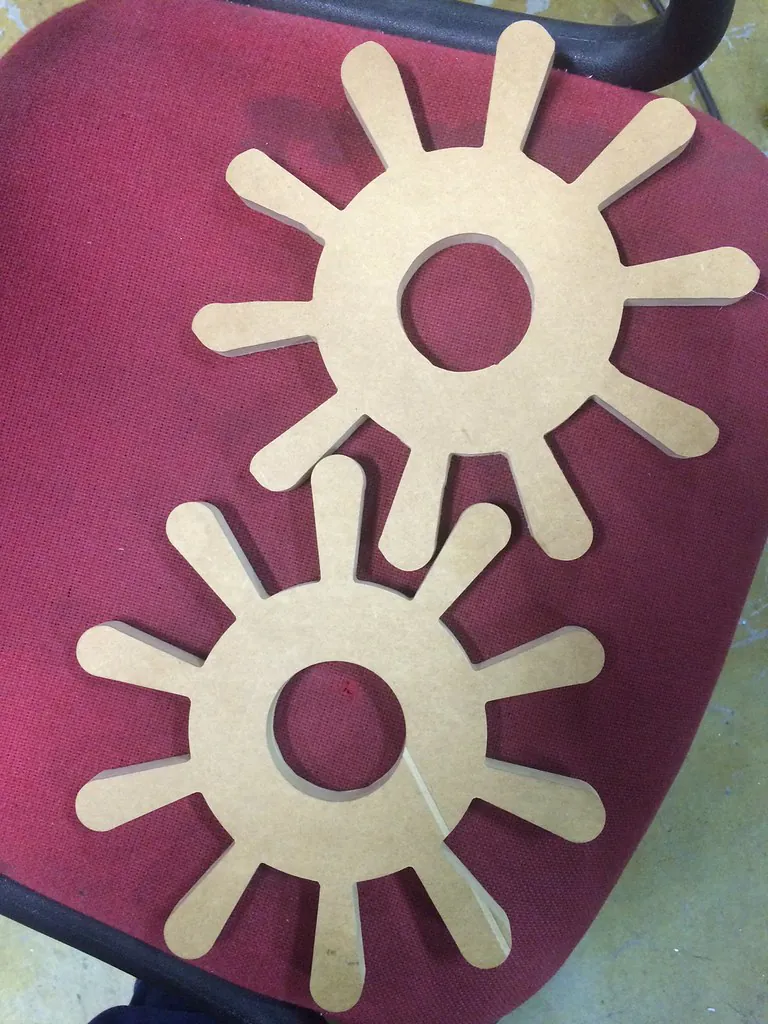
More detail of the correct result on the small 3040 cnc router:
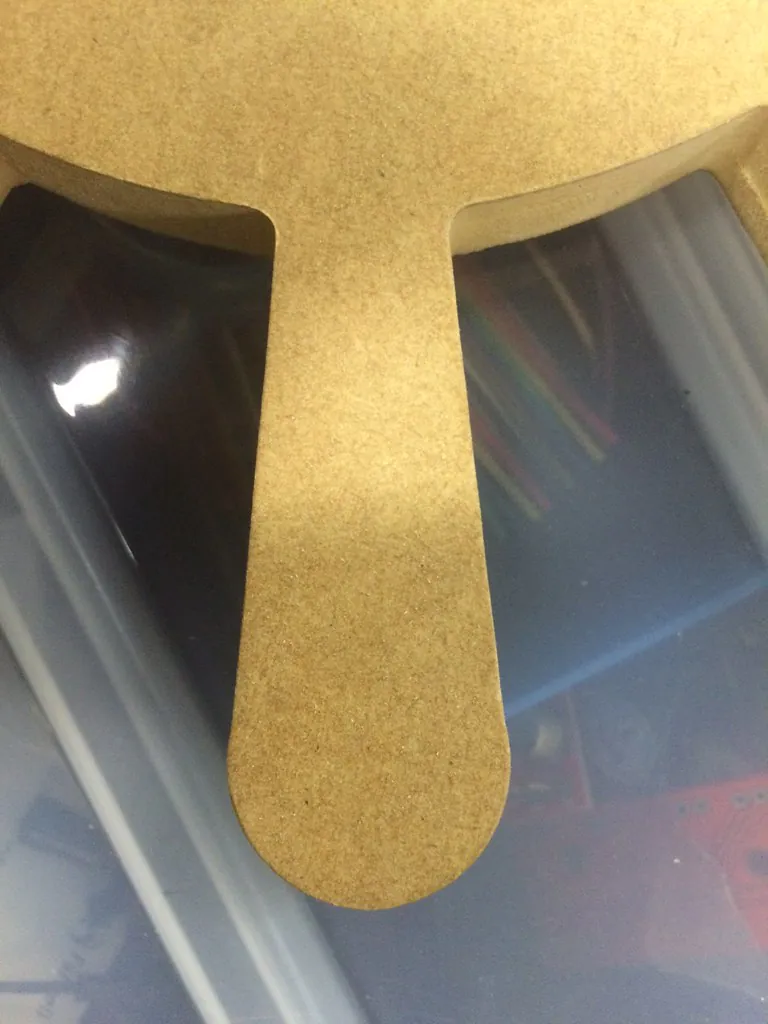
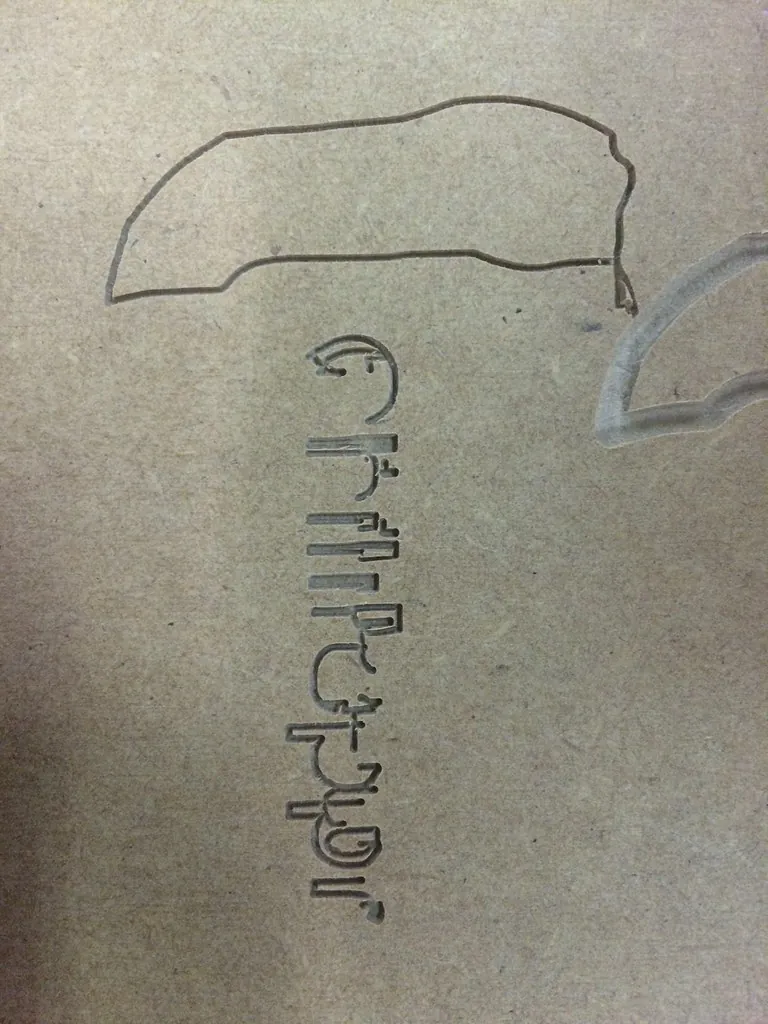
More detail of the result on the large wood router:
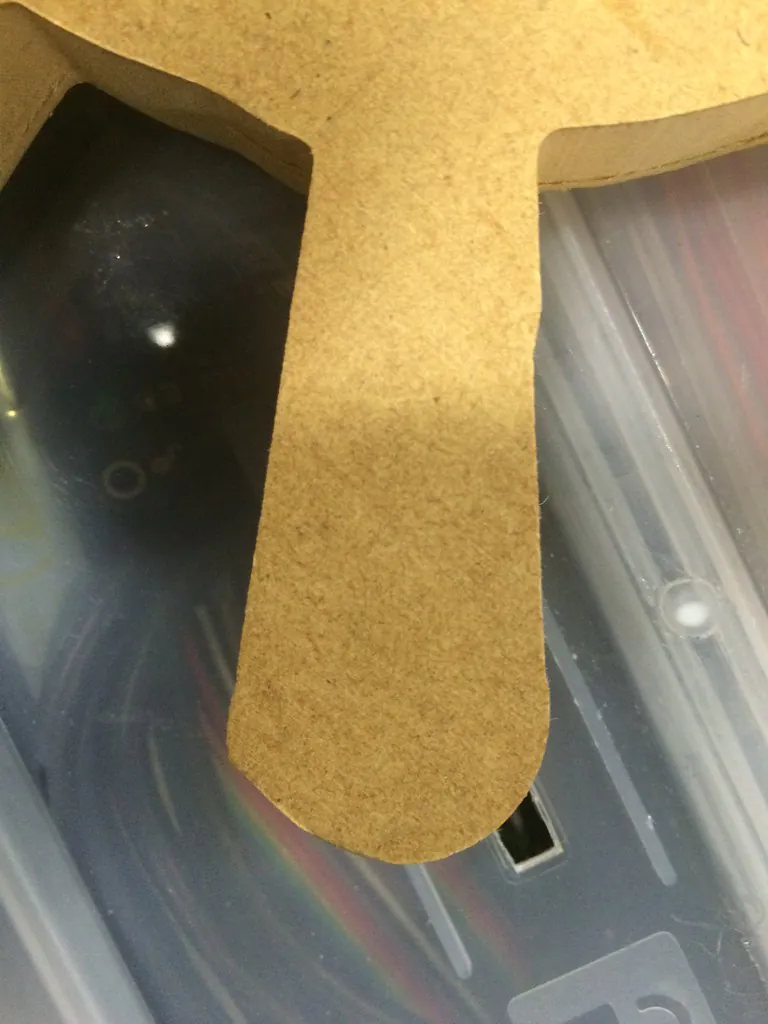
Also an example of a circle. In Chilipeppr it looks like a perfect circle:
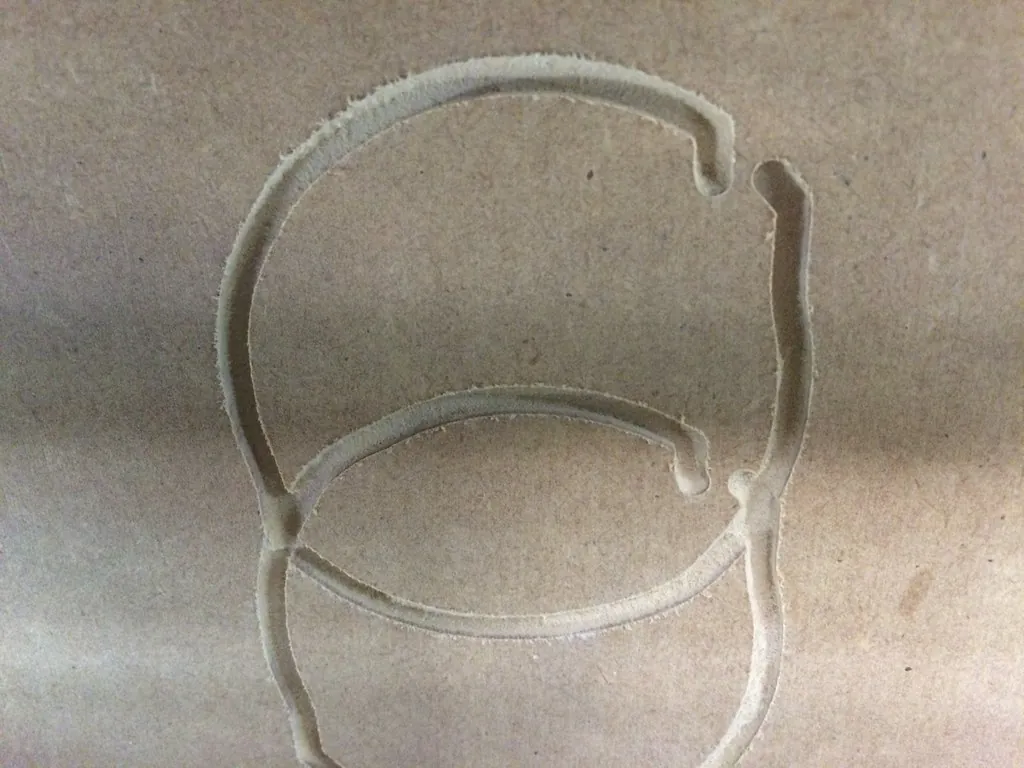
This is the code for the circle:
G21G17
M6
M3
G4 3
G0 X0.0000 Y0.0000 Z2.5400
G0 X-21.2205 Y-21.2934
G1 Z-2.0000 F200.0
G3 X21.2396 Y21.3326 F2000.0 I21.230 J21.313
G3 X-21.2205 Y-21.2934 I-21.230 J-21.313
G0 Z2.5400
M5
And finally the Chilipeppr demo:
I don't think we're experiencing loss of pulses because the spindle returns to the check location perfectly. We've played with microstepping, Chordal tolerances and junction deviation but all the same results. We also tried running the same shape without curve fitting (no g2 or g3 only g0 and g1 codes) with the same result.
We're running NEMA23 2.5A/10mH/2.5Nm steppers with two of them on the Gantry (motor 2 and 4) and 30Volts on the TinyG. The poulies on the X and Y have a circumference of approx 120mm. Z has a TR (travel per revolution) of only 5mm.
Could someone point us in the right direction? We've been searching the wiki's and fora's but with no luck.
Kind regards,
Frank and Bram
Here the TinyG dump:
[fb] firmware build 438.02
[fb] firmware build 438.02
[fv] firmware version 0.97
[hp] hardware platform 1.00
[hv] hardware version 8.00
[id] TinyG ID 3X3566-SPB
[fv] firmware version 0.97
[hp] hardware platform 1.00
[hv] hardware version 8.00
[id] TinyG ID 3X3566-SPB
[ja] junction acceleration 100000 mm
[ct] chordal tolerance 0.0100 mm
[ja] junction acceleration 100000 mm
[ct] chordal tolerance 0.0100 mm
[sl] soft limit enable 0
[st] switch type 1 [0=NO,1=NC]
[sl] soft limit enable 0
[st] switch type 1 [0=NO,1=NC]
[mt] motor idle timeout 2.00 Sec
[ej] enable json mode 0 [0=text,1=JSON]
[mt] motor idle timeout 2.00 Sec
[ej] enable json mode 0 [0=text,1=JSON]
[jv] json verbosity 1 [0=silent,1=footer,2=messages,3=configs,4=linenum,5=verbose]
[js] json serialize style 1 [0=relaxed,1=strict]
[jv] json verbosity 1 [0=silent,1=footer,2=messages,3=configs,4=linenum,5=verbose]
[js] json serialize style 1 [0=relaxed,1=strict]
[tv] text verbosity 0 [0=silent,1=verbose]
[qv] queue report verbosity 2 [0=off,1=single,2=triple]
[tv] text verbosity 0 [0=silent,1=verbose]
[qv] queue report verbosity 2 [0=off,1=single,2=triple]
[sv] status report verbosity 1 [0=off,1=filtered,2=verbose]
[si] status interval 250 ms
[ec] expand LF to CRLF on TX 0 [0=off,1=on]
[ee] enable echo 0 [0=off,1=on]
[ex] enable flow control 1 [0=off,1=XON/XOFF, 2=RTS/CTS]
[baud] USB baud rate 5 [1=9600,2=19200,3=38400,4=57600,5=115200,6=230400]
[net] network mode 0 [0=master]
[gpl] default gcode plane 0 [0=G17,1=G18,2=G19]
[sv] status report verbosity 1 [0=off,1=filtered,2=verbose]
[si] status interval 250 ms
[ec] expand LF to CRLF on TX 0 [0=off,1=on]
[ee] enable echo 0 [0=off,1=on]
[ex] enable flow control 1 [0=off,1=XON/XOFF, 2=RTS/CTS]
[baud] USB baud rate 5 [1=9600,2=19200,3=38400,4=57600,5=115200,6=230400]
[net] network mode 0 [0=master]
[gpl] default gcode plane 0 [0=G17,1=G18,2=G19]
[gun] default gcode units mode 1 [0=G20,1=G21]
[gco] default gcode coord system 1 [1-6 (G54-G59)]
[gun] default gcode units mode 1 [0=G20,1=G21]
[gco] default gcode coord system 1 [1-6 (G54-G59)]
[gpa] default gcode path control 2 [0=G61,1=G61.1,2=G64]
[gdi] default gcode distance mode 0 [0=G90,1=G91]
[gpa] default gcode path control 2 [0=G61,1=G61.1,2=G64]
[gdi] default gcode distance mode 0 [0=G90,1=G91]
[1ma] m1 map to axis 0 [0=X,1=Y,2=Z...]
[1sa] m1 step angle 1.800 deg
[1ma] m1 map to axis 0 [0=X,1=Y,2=Z...]
[1sa] m1 step angle 1.800 deg
[1tr] m1 travel per revolution 120.0100 mm
[1mi] m1 microsteps 8 [1,2,4,8]
[1tr] m1 travel per revolution 120.0100 mm
[1mi] m1 microsteps 8 [1,2,4,8]
[1po] m1 polarity 0 [0=normal,1=reverse]
[1pm] m1 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[1po] m1 polarity 0 [0=normal,1=reverse]
[1pm] m1 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[2ma] m2 map to axis 1 [0=X,1=Y,2=Z...]
[2sa] m2 step angle 1.800 deg
[2tr] m2 travel per revolution 119.4127 mm
[2ma] m2 map to axis 1 [0=X,1=Y,2=Z...]
[2sa] m2 step angle 1.800 deg
[2mi] m2 microsteps 8 [1,2,4,8]
[2po] m2 polarity 1 [0=normal,1=reverse]
[2pm] m2 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[2tr] m2 travel per revolution 119.4127 mm
[2mi] m2 microsteps 8 [1,2,4,8]
[2po] m2 polarity 1 [0=normal,1=reverse]
[2pm] m2 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[3ma] m3 map to axis 2 [0=X,1=Y,2=Z...]
[3sa] m3 step angle 1.800 deg
[3ma] m3 map to axis 2 [0=X,1=Y,2=Z...]
[3sa] m3 step angle 1.800 deg
[3tr] m3 travel per revolution 5.0000 mm
[3mi] m3 microsteps 8 [1,2,4,8]
[3tr] m3 travel per revolution 5.0000 mm
[3mi] m3 microsteps 8 [1,2,4,8]
[3po] m3 polarity 0 [0=normal,1=reverse]
[3po] m3 polarity 0 [0=normal,1=reverse]
[3pm] m3 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[3pm] m3 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[4ma] m4 map to axis 1 [0=X,1=Y,2=Z...]
[4sa] m4 step angle 1.800 deg
[4ma] m4 map to axis 1 [0=X,1=Y,2=Z...]
[4sa] m4 step angle 1.800 deg
[4tr] m4 travel per revolution 119.4127 mm
[4mi] m4 microsteps 8 [1,2,4,8]
[4tr] m4 travel per revolution 119.4127 mm
[4mi] m4 microsteps 8 [1,2,4,8]
[4po] m4 polarity 0 [0=normal,1=reverse]
[4pm] m4 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[4po] m4 polarity 0 [0=normal,1=reverse]
[4pm] m4 power management 1 [0=disabled,1=always on,2=in cycle,3=when moving]
[xam] x axis mode 1 [standard]
[xam] x axis mode 1 [standard]
[xvm] x velocity maximum 30000 mm/min
[xfr] x feedrate maximum 1000 mm/min
[xvm] x velocity maximum 30000 mm/min
[xfr] x feedrate maximum 1000 mm/min
[xtn] x travel minimum 0.000 mm
[xtn] x travel minimum 0.000 mm
[xtm] x travel maximum 150.000 mm
[xjm] x jerk maximum 100 mm/min^3 * 1 million
[xtm] x travel maximum 150.000 mm
[xjm] x jerk maximum 100 mm/min^3 * 1 million
[xjh] x jerk homing 20 mm/min^3 * 1 million
[xjd] x junction deviation 0.0500 mm (larger is faster)
[xjh] x jerk homing 20 mm/min^3 * 1 million
[xjd] x junction deviation 0.0500 mm (larger is faster)
[xsn] x switch min 0 [0=off,1=homing,2=limit,3=limit+homing]
[xsx] x switch max 0 [0=off,1=homing,2=limit,3=limit+homing]
[xsn] x switch min 0 [0=off,1=homing,2=limit,3=limit+homing]
[xsx] x switch max 0 [0=off,1=homing,2=limit,3=limit+homing]
[xsv] x search velocity 500 mm/min
[xlv] x latch velocity 100 mm/min
[xsv] x search velocity 500 mm/min
[xlv] x latch velocity 100 mm/min
[xlb] x latch backoff 5.000 mm
[xlb] x latch backoff 5.000 mm
[xzb] x zero backoff 1.000 mm
[yam] y axis mode 1 [standard]
[yvm] y velocity maximum 20000 mm/min
[xzb] x zero backoff 1.000 mm
[yam] y axis mode 1 [standard]
[yvm] y velocity maximum 20000 mm/min
[yfr] y feedrate maximum 1000 mm/min
[ytn] y travel minimum 0.000 mm
[yfr] y feedrate maximum 1000 mm/min
[ytn] y travel minimum 0.000 mm
[ytm] y travel maximum 150.000 mm
[ytm] y travel maximum 150.000 mm
[yjm] y jerk maximum 50 mm/min^3 * 1 million
[yjh] y jerk homing 20 mm/min^3 * 1 million
[yjm] y jerk maximum 50 mm/min^3 * 1 million
[yjh] y jerk homing 20 mm/min^3 * 1 million
[yjd] y junction deviation 0.0500 mm (larger is faster)
[yjd] y junction deviation 0.0500 mm (larger is faster)
[ysn] y switch min 1 [0=off,1=homing,2=limit,3=limit+homing]
[ysx] y switch max 0 [0=off,1=homing,2=limit,3=limit+homing]
[ysn] y switch min 1 [0=off,1=homing,2=limit,3=limit+homing]
[ysx] y switch max 0 [0=off,1=homing,2=limit,3=limit+homing]
[ysv] y search velocity 1000 mm/min
[ylv] y latch velocity 1000 mm/min
[ysv] y search velocity 1000 mm/min
[ylv] y latch velocity 1000 mm/min
[ylb] y latch backoff 5.000 mm
[yzb] y zero backoff 1.000 mm
[ylb] y latch backoff 5.000 mm
[yzb] y zero backoff 1.000 mm
[zam] z axis mode 1 [standard]
[zvm] z velocity maximum 5000 mm/min
[zam] z axis mode 1 [standard]
[zvm] z velocity maximum 5000 mm/min
[zfr] z feedrate maximum 1000 mm/min
[ztn] z travel minimum 0.000 mm
[zfr] z feedrate maximum 1000 mm/min
[ztn] z travel minimum 0.000 mm
[ztm] z travel maximum 75.000 mm
[zjm] z jerk maximum 50 mm/min^3 * 1 million
[ztm] z travel maximum 75.000 mm
[zjm] z jerk maximum 50 mm/min^3 * 1 million
[zjh] z jerk homing 20 mm/min^3 * 1 million
[zjd] z junction deviation 0.0500 mm (larger is faster)
[zjh] z jerk homing 20 mm/min^3 * 1 million
[zjd] z junction deviation 0.0500 mm (larger is faster)
[zsn] z switch min 0 [0=off,1=homing,2=limit,3=limit+homing]
[zsx] z switch max 1 [0=off,1=homing,2=limit,3=limit+homing]
[zsn] z switch min 0 [0=off,1=homing,2=limit,3=limit+homing]
[zsx] z switch max 1 [0=off,1=homing,2=limit,3=limit+homing]
[zsv] z search velocity 400 mm/min
[zlv] z latch velocity 100 mm/min
[zsv] z search velocity 400 mm/min
[zlv] z latch velocity 100 mm/min
[zlb] z latch backoff 5.000 mm
[zzb] z zero backoff 1.000 mm
[zlb] z latch backoff 5.000 mm
[zzb] z zero backoff 1.000 mm
[aam] a axis mode 1 [standard]
[avm] a velocity maximum 230400 deg/min
[aam] a axis mode 1 [standard]
[avm] a velocity maximum 230400 deg/min
[afr] a feedrate maximum 230400 deg/min
[atn] a travel minimum -1.000 deg
[afr] a feedrate maximum 230400 deg/min
[atn] a travel minimum -1.000 deg
[atm] a travel maximum -1.000 deg
[ajm] a jerk maximum 5760 deg/min^3 * 1 million
[atm] a travel maximum -1.000 deg
[ajm] a jerk maximum 5760 deg/min^3 * 1 million
[ajh] a jerk homing 5760 deg/min^3 * 1 million
[ajd] a junction deviation 0.0500 deg (larger is faster)
[ajh] a jerk homing 5760 deg/min^3 * 1 million
[ajd] a junction deviation 0.0500 deg (larger is faster)
[ara] a radius value 0.1990 deg
[asn] a switch min 1 [0=off,1=homing,2=limit,3=limit+homing]
[ara] a radius value 0.1990 deg
[asn] a switch min 1 [0=off,1=homing,2=limit,3=limit+homing]
[asx] a switch max 0 [0=off,1=homing,2=limit,3=limit+homing]
[asv] a search velocity 600 deg/min
[asx] a switch max 0 [0=off,1=homing,2=limit,3=limit+homing]
[asv] a search velocity 600 deg/min
[alv] a latch velocity 100 deg/min
[alb] a latch backoff 5.000 deg
[alv] a latch velocity 100 deg/min
[alb] a latch backoff 5.000 deg
[azb] a zero backoff 2.000 deg
[bam] b axis mode 0 [disabled]
[azb] a zero backoff 2.000 deg
[bam] b axis mode 0 [disabled]
[bvm] b velocity maximum 3600 deg/min
[bfr] b feedrate maximum 3600 deg/min
[bvm] b velocity maximum 3600 deg/min
[bfr] b feedrate maximum 3600 deg/min
[btn] b travel minimum -1.000 deg
[btm] b travel maximum -1.000 deg
[btn] b travel minimum -1.000 deg
[btm] b travel maximum -1.000 deg
[bjm] b jerk maximum 20 deg/min^3 * 1 million
[bjd] b junction deviation 0.0500 deg (larger is faster)
[bjm] b jerk maximum 20 deg/min^3 * 1 million
[bjd] b junction deviation 0.0500 deg (larger is faster)
[bra] b radius value 1.0000 deg
[cam] c axis mode 0 [disabled]
[bra] b radius value 1.0000 deg
[cam] c axis mode 0 [disabled]
[cvm] c velocity maximum 3600 deg/min
[cfr] c feedrate maximum 3600 deg/min
[cvm] c velocity maximum 3600 deg/min
[cfr] c feedrate maximum 3600 deg/min
[ctn] c travel minimum -1.000 deg
[ctm] c travel maximum -1.000 deg
[ctn] c travel minimum -1.000 deg
[ctm] c travel maximum -1.000 deg
[cjm] c jerk maximum 20 deg/min^3 * 1 million
[cjd] c junction deviation 0.0500 deg (larger is faster)
[cjm] c jerk maximum 20 deg/min^3 * 1 million
[cjd] c junction deviation 0.0500 deg (larger is faster)
[cra] c radius value 1.0000 deg
[p1frq] pwm frequency 100 Hz
[cra] c radius value 1.0000 deg
[p1frq] pwm frequency 100 Hz
[p1csl] pwm cw speed lo 1000 RPM
[p1csh] pwm cw speed hi 2000 RPM
[p1csl] pwm cw speed lo 1000 RPM
[p1csh] pwm cw speed hi 2000 RPM
[p1cpl] pwm cw phase lo 0.125 [0..1]
[p1cph] pwm cw phase hi 0.200 [0..1]
[p1cpl] pwm cw phase lo 0.125 [0..1]
[p1cph] pwm cw phase hi 0.200 [0..1]
[p1wsl] pwm ccw speed lo 1000 RPM
[p1wsh] pwm ccw speed hi 2000 RPM
[p1wsl] pwm ccw speed lo 1000 RPM
[p1wsh] pwm ccw speed hi 2000 RPM
[p1wpl] pwm ccw phase lo 0.125 [0..1]
[p1wph] pwm ccw phase hi 0.200 [0..1]
[p1wpl] pwm ccw phase lo 0.125 [0..1]
[p1wph] pwm ccw phase hi 0.200 [0..1]
[p1pof] pwm phase off 0.100 [0..1]
[g54x] g54 x offset 0.000 mm
[p1pof] pwm phase off 0.100 [0..1]
[g54x] g54 x offset 0.000 mm
[g54y] g54 y offset 0.000 mm
[g54z] g54 z offset 0.000 mm
[g54y] g54 y offset 0.000 mm
[g54z] g54 z offset 0.000 mm
[g54a] g54 a offset 0.000 deg
[g54b] g54 b offset 0.000 deg
[g54a] g54 a offset 0.000 deg
[g54b] g54 b offset 0.000 deg
[g54c] g54 c offset 0.000 deg
[g55x] g55 x offset 75.000 mm
[g54c] g54 c offset 0.000 deg
[g55x] g55 x offset 75.000 mm
[g55y] g55 y offset 75.000 mm
[g55z] g55 z offset 0.000 mm
[g55y] g55 y offset 75.000 mm
[g55z] g55 z offset 0.000 mm
[g55a] g55 a offset 0.000 deg
[g55b] g55 b offset 0.000 deg
[g55a] g55 a offset 0.000 deg
[g55b] g55 b offset 0.000 deg
[g55c] g55 c offset 0.000 deg
[g56x] g56 x offset 0.000 mm
[g55c] g55 c offset 0.000 deg
[g56x] g56 x offset 0.000 mm
[g56y] g56 y offset 0.000 mm
[g56z] g56 z offset 0.000 mm
[g56y] g56 y offset 0.000 mm
[g56z] g56 z offset 0.000 mm
[g56a] g56 a offset 0.000 deg
[g56b] g56 b offset 0.000 deg
[g56a] g56 a offset 0.000 deg
[g56b] g56 b offset 0.000 deg
[g56c] g56 c offset 0.000 deg
[g57x] g57 x offset 0.000 mm
[g56c] g56 c offset 0.000 deg
[g57x] g57 x offset 0.000 mm
[g57y] g57 y offset 0.000 mm
[g57z] g57 z offset 0.000 mm
[g57y] g57 y offset 0.000 mm
[g57z] g57 z offset 0.000 mm
[g57a] g57 a offset 0.000 deg
[g57b] g57 b offset 0.000 deg
[g57a] g57 a offset 0.000 deg
[g57b] g57 b offset 0.000 deg
[g57c] g57 c offset 0.000 deg
[g58x] g58 x offset 0.000 mm
[g57c] g57 c offset 0.000 deg
[g58x] g58 x offset 0.000 mm
[g58y] g58 y offset 0.000 mm
[g58z] g58 z offset 0.000 mm
[g58y] g58 y offset 0.000 mm
[g58z] g58 z offset 0.000 mm
[g58a] g58 a offset 0.000 deg
[g58b] g58 b offset 0.000 deg
[g58a] g58 a offset 0.000 deg
[g58b] g58 b offset 0.000 deg
[g58c] g58 c offset 0.000 deg
[g59x] g59 x offset 0.000 mm
[g58c] g58 c offset 0.000 deg
[g59x] g59 x offset 0.000 mm
[g59y] g59 y offset 0.000 mm
[g59z] g59 z offset 0.000 mm
[g59y] g59 y offset 0.000 mm
[g59z] g59 z offset 0.000 mm
[g59a] g59 a offset 0.000 deg
[g59b] g59 b offset 0.000 deg
[g59a] g59 a offset 0.000 deg
[g59b] g59 b offset 0.000 deg
[g59c] g59 c offset 0.000 deg
[g92x] g92 x offset 0.000 mm
[g59c] g59 c offset 0.000 deg
[g92x] g92 x offset 0.000 mm
[g92y] g92 y offset 0.000 mm
[g92z] g92 z offset 0.000 mm
[g92y] g92 y offset 0.000 mm
[g92z] g92 z offset 0.000 mm
[g92a] g92 a offset 0.000 deg
[g92b] g92 b offset 0.000 deg
[g92a] g92 a offset 0.000 deg
[g92b] g92 b offset 0.000 deg
[g92c] g92 c offset 0.000 deg
[g28x] g28 x position 0.000 mm
[g92c] g92 c offset 0.000 deg
[g28x] g28 x position 0.000 mm
[g28y] g28 y position 0.000 mm
[g28z] g28 z position 0.000 mm
[g28y] g28 y position 0.000 mm
[g28z] g28 z position 0.000 mm
[g28a] g28 a position 0.000 deg
[g28b] g28 b position 0.000 deg
[g28a] g28 a position 0.000 deg
[g28b] g28 b position 0.000 deg
[g28c] g28 c position 0.000 deg
[g30x] g30 x position 0.000 mm
[g28c] g28 c position 0.000 deg
[g30x] g30 x position 0.000 mm
[g30y] g30 y position 0.000 mm
[g30z] g30 z position 0.000 mm
[g30y] g30 y position 0.000 mm
[g30z] g30 z position 0.000 mm
[g30a] g30 a position 0.000 deg
[g30b] g30 b position 0.000 deg
[g30a] g30 a position 0.000 deg
[g30b] g30 b position 0.000 deg
[g30c] g30 c position 0.000 deg
[g30c] g30 c position 0.000 deg